Physicl raises 10M to bridge the simulation-to-reality gap for robots
Physicl has secured $10M in seed funding to create high-fidelity 3D environments, helping robots learn to interact with the physical world more effectively.
Physicl, a startup founded by Alex de Vigan, has raised $10 million in seed funding led by Inovia Capital. The company aims to solve the sim-to-real gap—the difficulty of translating training from virtual simulations to real-world performance—by providing high-fidelity 3D environments for robot training.
- Physicl repurposed its e-commerce 3D rendering pipeline for robotics application.
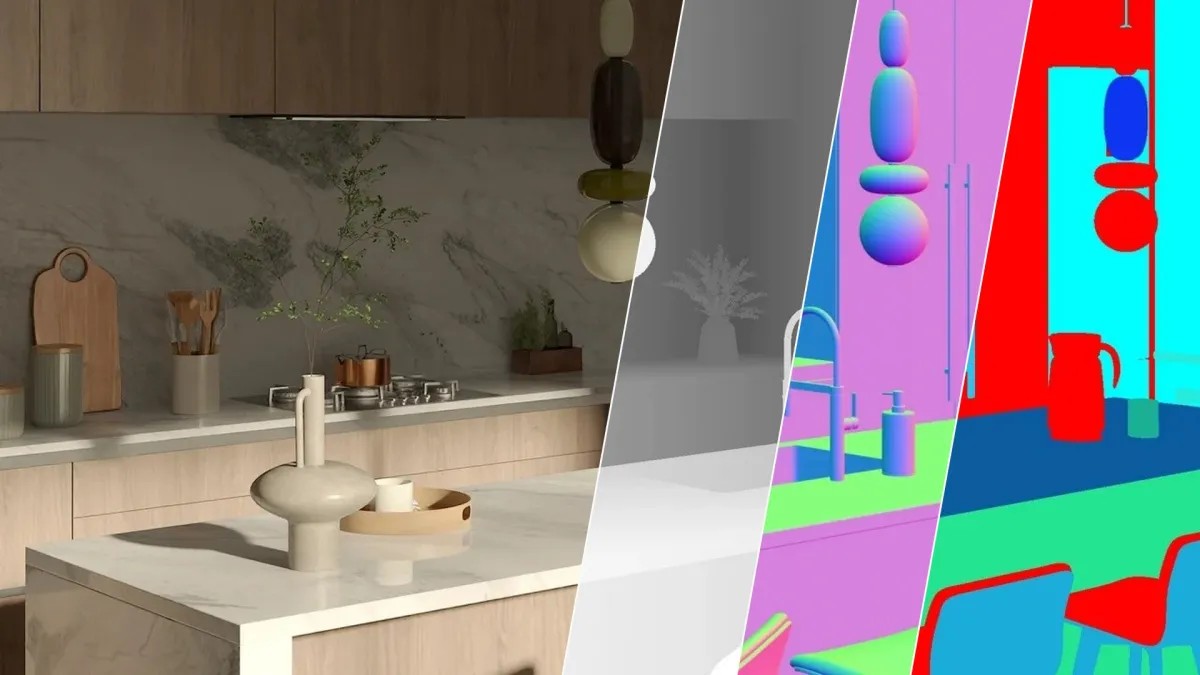
- The 'Studio' product features 10,000 environments and 100,000 assets for synthetic data generation.
- It focuses on 'edge cases,' helping robots handle cluttered spaces, shadows, and complex objects.
- The platform supports continuous, agentic workflows where models request specific data during training.
Repurposing technology for AI
Alex de Vigan previously led nfinite, which specialized in creating 3D product renderings for online retail. With the emergence of transformer-based models, de Vigan saw an opportunity to apply their sophisticated spatial rendering tech to robotics. While AI models excelled at generating images, they often lacked the ability to interact and manipulate objects in 3D space with physical accuracy.
Physicl bridges this by transforming unstructured, heterogeneous real-world data into high-fidelity physical representations. This ensures that when robots are trained in these simulations, the geometry, materials, and physics align with real-world constraints, making the training significantly more effective than traditional video-based methods.
Read alsoChina blocks SoftBank from acquiring ABB robotics unit in $5.4 billion dealTackling the 'Edge Cases'
The startup's primary offering, Studio, is designed for training models on challenging scenarios that robots frequently struggle with. By generating synthetic data on-the-fly, the platform allows developers to create countless variations of a scene—such as objects hidden in shadows or cluttered countertops—enabling the robot to generalize its skills.
Early adopter SpAItial used Physicl's high-fidelity data to improve their 'Echo-3' model. As SpAItial CEO Matthias Niessner noted, the ability to generate training data dynamically based on the current training state is a massive breakthrough, replacing long, manual cycles of data curation with efficient automation.
What this means for the industry
For the robotics and foundation model sector, Physicl signals a shift toward agentic data workflows. As models become more capable, they will effectively manage their own training datasets by identifying knowledge gaps and triggering the generation of missing data scenarios. For global developers and tech hubs, this ecosystem approach to synthetic data is becoming the new standard for deploying autonomous agents into the real world.
Source: TechCrunch